True-state simulation · known obstacle geometry
Obstacle navigation
Completion in known obstacle layouts
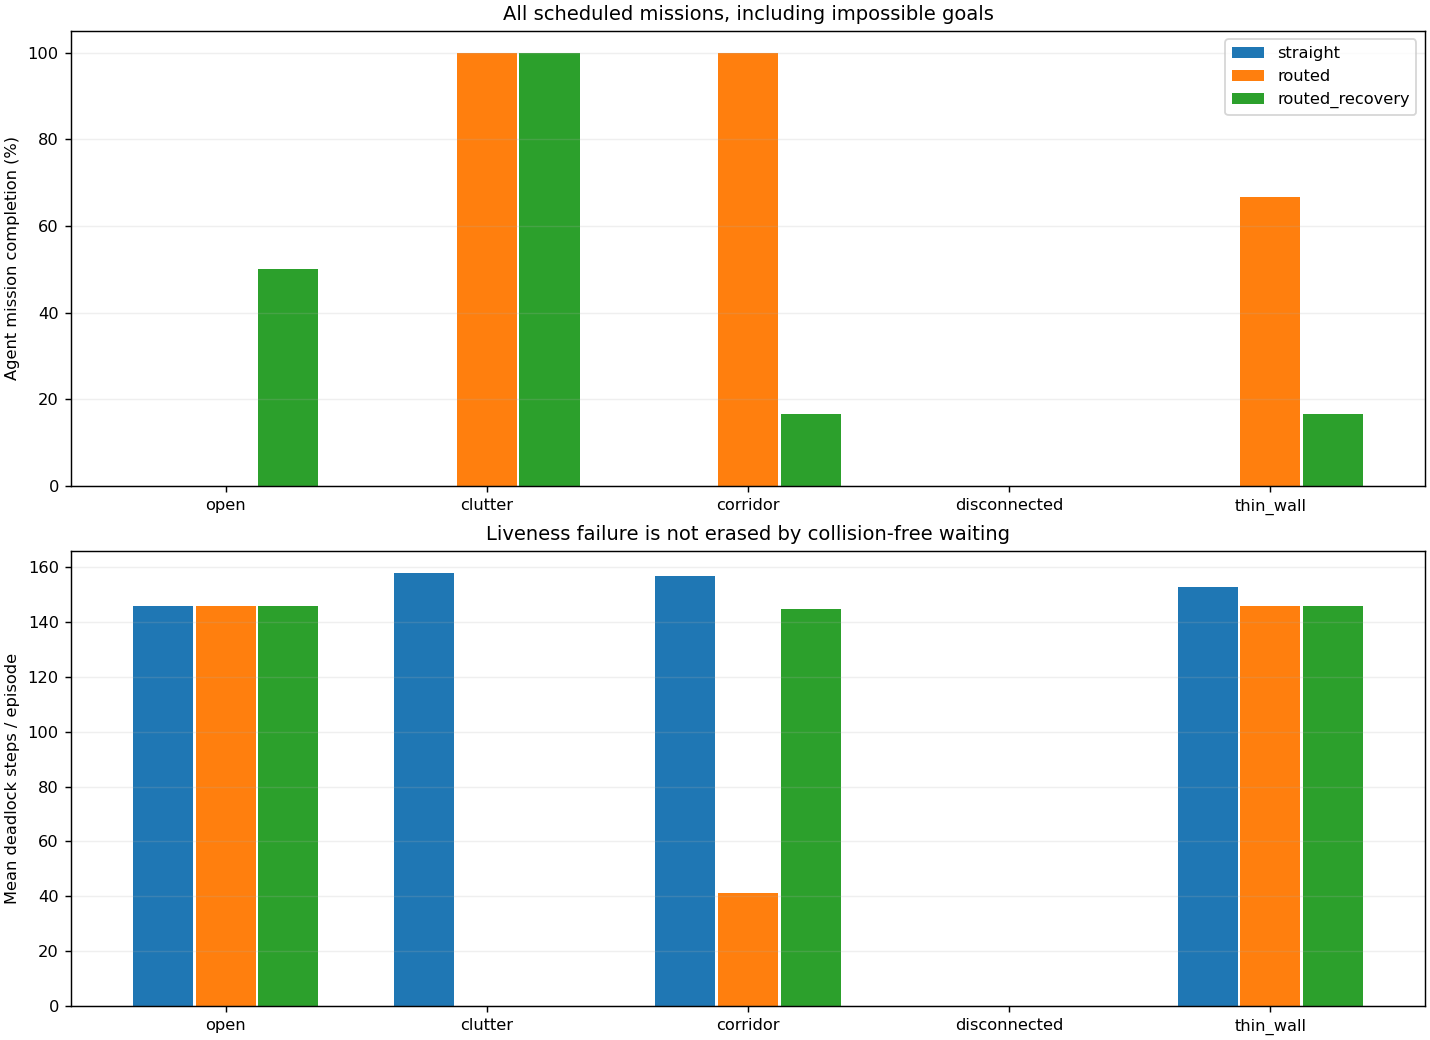
Mixed completion outcomes. 432 agents completed; 288 were unreachable and 720 timed out.
- Simulation episodes
- 240
- 1,440 scheduled agent missions
- Completed agents
- 432
- 30% of all scheduled agents
- Unreachable agents
- 288
- Retained in the denominator
- Timed-out agents
- 720
- 50% of all scheduled agents
Recorded evidence
Results
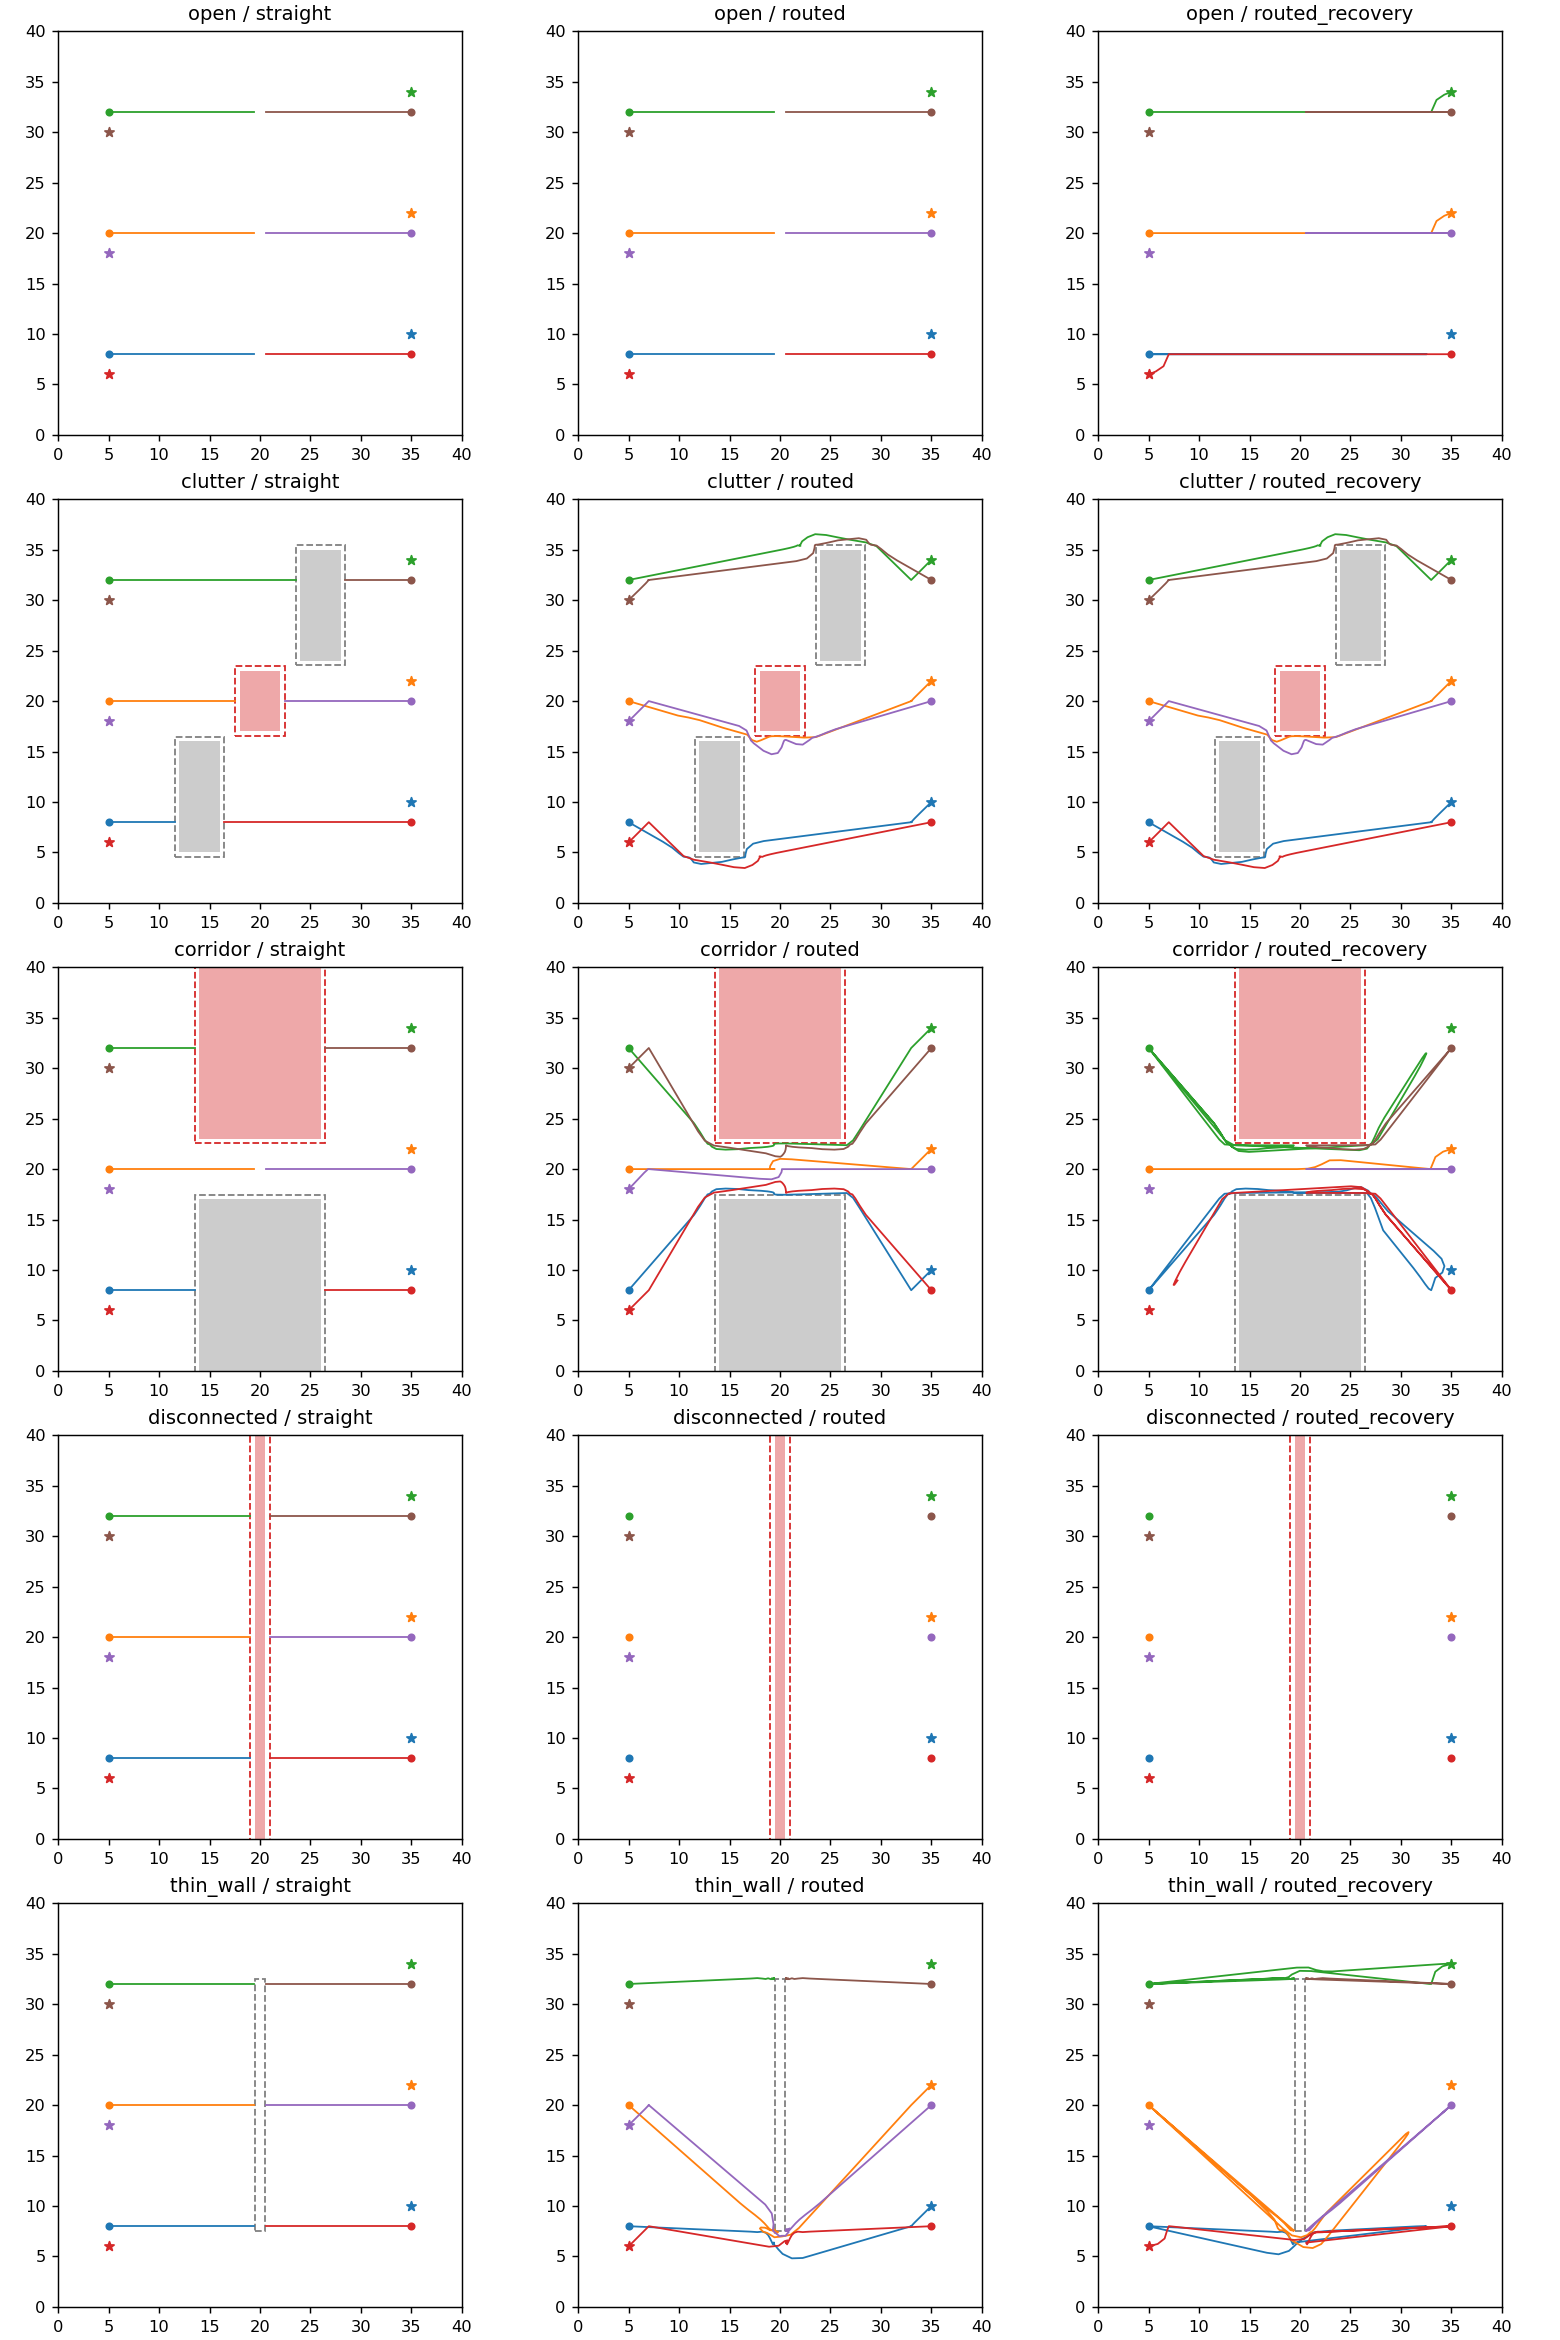
Three planners across five layouts, with every scheduled agent retained.
Case 1 of 15open · straight
| Outcome / metric | Straight baseline | straight |
|---|---|---|
| Completed agents | 0 | 0 |
| Unreachable agents | 0 | 0 |
| Timed-out agents | 96 | 96 |
| Runtime-error agents | 0 | 0 |
| Deadlock occupancy / episode-steps | 2,336 | 2,336 |
| Mean flown distance m | 14.4 | 14.4 |
| Completed-only time s | null | null |
| Metric | Value |
|---|---|
| Recovery minus routed completions | 48 |
| Scheduled agents per cell | 96 |
Case notes & acceptance
Null completion time means no completed agents.
null = missing or not applicable, never zero. Intervals and sample sizes are reported in each table. Scroll tables horizontally to see every column.
Report figures
Methods & interpretation
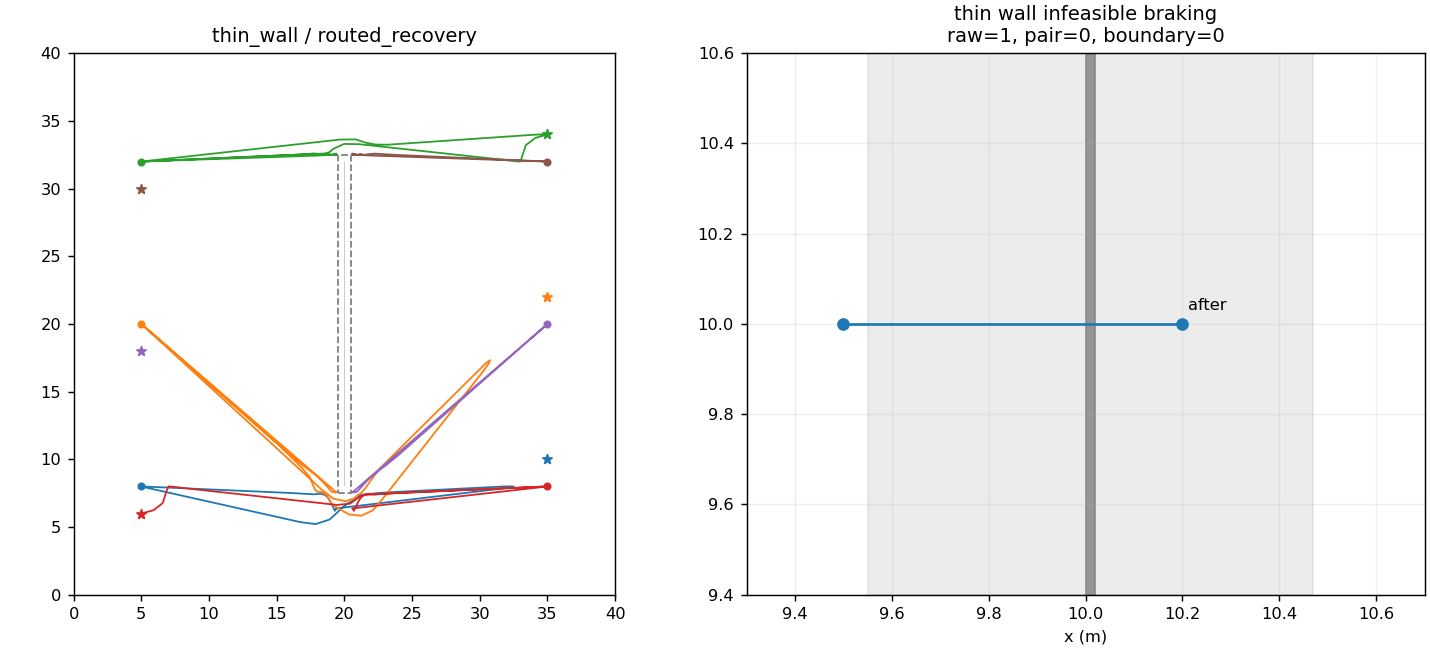
Recovery reduces completions in corridor and thin-wall layouts. The hardened 240 jobs duplicate the original schedule: do not add them to the original 240 or their replays. True-state, known-geometry oracle; bounded braking does not guarantee avoidance in adversarial states. Fixed motion geometry repeats across mapping seeds; no independent geometric-trial CI. Null completion time is not zero.